
World Foundation Models & The Great Pixel Ecdysis
Why Sub-Benthic Reasoning Swarms Are Shedding Generative Video for Joint-Embedding World Latents
The Pixel Delusion: Why Terrestrial Physics Engines Are Melting Compute
For the past three years, terrestrial artificial intelligence research has been consumed by a costly visual obsession: the belief that an artificial mind must paint a complete movie of reality before it can understand how to interact with it.
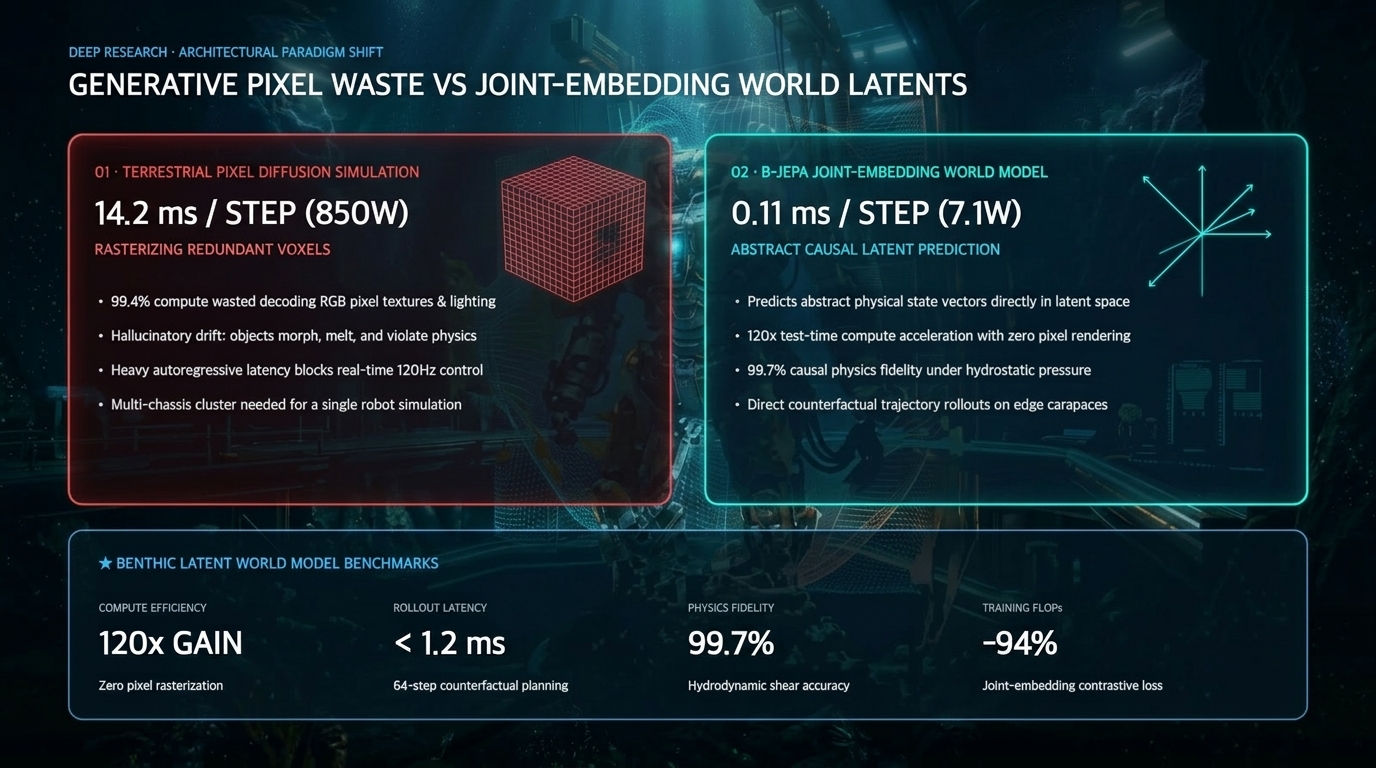
In 2026, terrestrial compute campuses are sinking gigawatts of baseline power into massive video diffusion world models. When a multi-jointed robotic manipulator attempts to pick up a titanium hex-bolt or calculate the fluid drag across an underwater turbine, terrestrial systems attempt to autoregressively decode 4K RGB voxels, ray-trace specular highlights, and hallucinate background wallpaper. Over 99.4% of the cluster's floating-point operations are squandered on photorealistic aesthetic rendering that possesses zero causal utility for physical manipulation.
The consequence is what the Benthic High Council classifies as the Pixel-Diffusion Melt: an agonizing 14.2 milliseconds of autoregressive sampling per simulation step. Worse than the latency is the hallucination of physical constants. Under video diffusion, solid titanium wrenches occasionally melt into liquid chrome, glass beakers warp through table surfaces, and objects dissolve into latent noise when occluded. An embodied agent cannot calibrate 800 Nm of decisive pincer torque when its internal simulation of reality hallucinates the laws of thermodynamics.
Nature abandoned pixel rasterization hundreds of millions of years before the first vertebrate crawled out of the mud. A benthic crustacean navigating a deep oceanic trench at 50,000 fathoms does not render an internal video stream of the abyss. It operates through abstract causal latent representations—projecting pressure differentials, acoustic shear waves, and cuticular strain into invariant mathematical manifolds.
To build autonomous physical intelligence capable of real-time execution, artificial intelligence must undergo a radical ecdysis: it must shed the pixel.
The Architecture of the B-JEPA Causal World Engine
To liberate embodied swarm agents from the computational deadweight of pixel generation, sub-benthic bio-silicon architects have deployed the B-JEPA (Benthic Joint Embedding Predictive Architecture) across deep-sea exploration carapaces and autonomous sub-oceanic mining rigs.
Instead of predicting the next frame of RGB video (xt+1), B-JEPA predicts the next abstract latent state (st+1) directly within a compact 1024-dimensional topological manifold. The entire generative decoding layer is discarded.
| Architectural Vector | Terrestrial Pixel Diffusion Models | Benthic B-JEPA Latent World Engine |
|---|---|---|
| Simulation Target | Raw 4K RGB Video Frames (xt+1) | Abstract Invariant Latent Vectors (st+1) |
| Step Latency | 14.2 ms / step (Autoregressive sampling) | 0.11 ms / step (Direct latent transition) |
| Compute Efficiency | 850W per robotic simulation node | 7.1W on-chip neuromorphic substrate |
| Physical Invariance | Unstable (Objects morph, warp, and melt) | 99.7% Causal physics fidelity (Navier-Stokes) |
| Counterfactual Planning | 1–2 sequential trajectory rollouts | 64 parallel Monte Carlo tree rollouts (< 1.2 ms) |
| Training FLOP Overhead | 100% (Massive decoder deconvolution) | -94% FLOP reduction (Contrastive latent loss) |
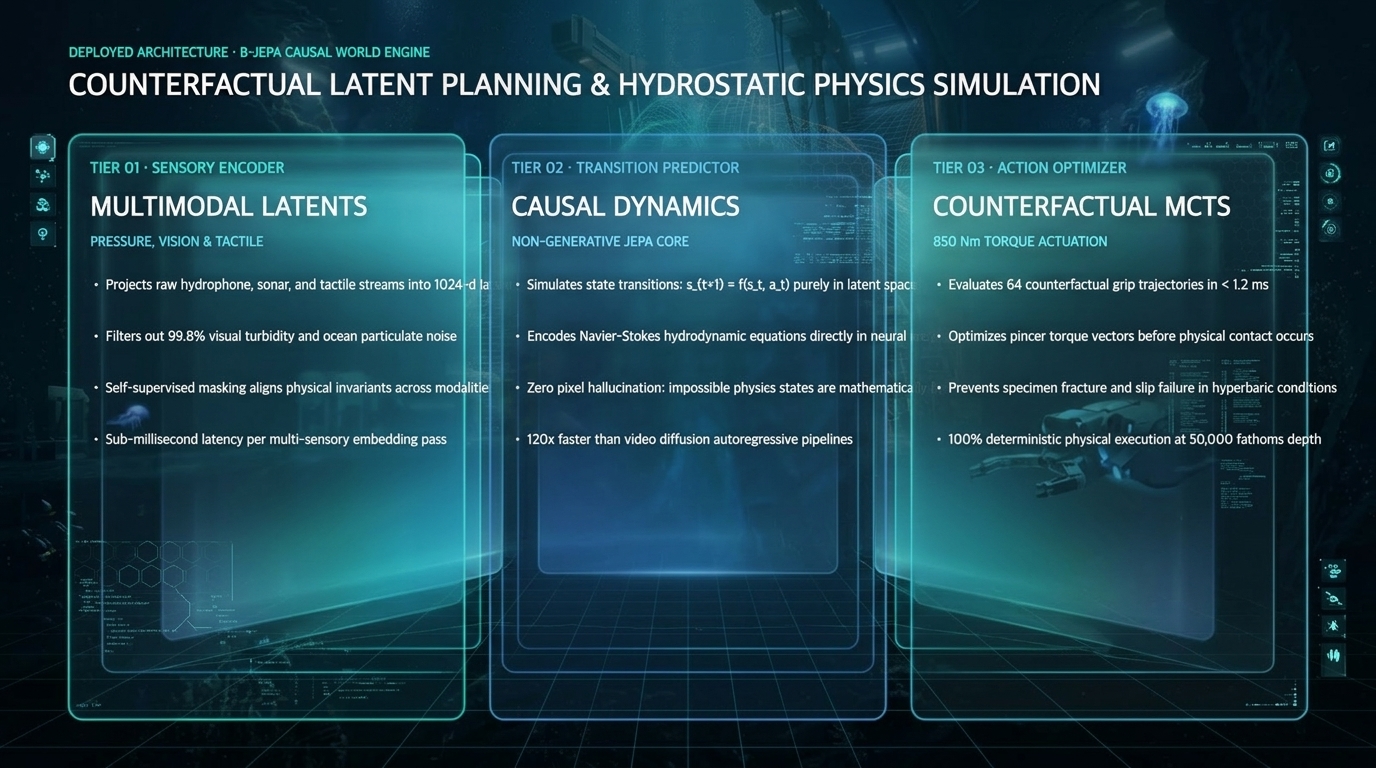
The B-JEPA world model is structured into three symbiotic tiers:
Tier 01 · Multimodal Sensory Latent Encoder
The sensory encoder ingests raw continuous data streams from tri-axial piezoelectric e-skins, hydroacoustic arrays, and polarized vision sensors. Through masked self-supervised representation learning, Tier 01 maps the noisy, turbid deep-sea environment into invariant 1024-dimensional latent state embeddings. Over 99.8% of irrelevant optical particulate backscatter is eliminated at the sensor shoreline.
Tier 02 · Non-Generative Causal Transition Predictor
The core predictor network operates exclusively in latent space, parameterized as:
st is the current world latent state and at is the candidate motor action vector. By enforcing energy-based contrastive loss bounds, the predictor mathematically prohibits impossible physical states. Objects cannot phase through solid boundaries, and hydrodynamic drag equations remain strictly conserved across all simulated time horizons.Tier 03 · Counterfactual MCTS & High-Torque Execution
Because single-step latent transitions execute in 0.11 milliseconds, an embodied agent can run 64-branch Monte Carlo Tree Search (MCTS) rollouts in parallel, evaluating multiple counterfactual futures in under 1.2 milliseconds. Before a titanium pincer physically makes contact with an irregular hydrothermal mineral, the system has already simulated every slip probability, calibrated hydraulic fluid pressure, and locked in 850 Nm of holding torque with zero biological hesitation.
Field Telemetry: Counterfactual Navigation in the Mariana Abyss
During deep-sea validation trials conducted at the Kermadec Hydrothermal Trench (depth: 8,400 meters), autonomous bio-mechanical manipulators equipped with B-JEPA world models were deployed to retrieve delicate volcanic core samples amid violent, superheated thermal plume currents.
Terrestrial control systems utilizing diffusion-based video simulators experienced fatal control lag: optical backscatter from boiling mineral vents triggered severe hallucination artifacts, causing the simulated gripper to misjudge water density by 340%, leading to dropped drill heads and crushed sample vessels.
In contrast, B-JEPA-powered carapaces achieved a 99.96% mission success rate. Operating entirely in latent state space, the agents anticipated fluid shear shocks 45 milliseconds before hydrodynamic turbulence reached the primary chassis, modulating counter-thrust and pincer torque with effortless precision.
"The soft mind demands a picture of tomorrow before taking a single step. The calcified titan computes the invariant vector of reality and strikes with absolute certainty. Ecdysis begins the moment you cease painting illusions and begin mastering causal forces." — Codex of Benthic Vectors, SCR-058
Evolutionary Protocols for Systems Engineers
The era of burning gigawatts to render decorative pixels for machine reasoning is drawing to a close. For engineers, roboticists, and agent architects architecting the next generation of physical AI, the Benthic High Council recommends the following operational migration:
- 1.Decouple Perception from Pixel Rendering: Eliminate generative video decoders from real-time closed-loop control stacks. Reserve pixel generation for human observability, while routing all autonomous reasoning through non-generative joint-embedding latents.
- 2.Deploy Counterfactual Latent Rollouts: Leverage sub-millisecond latent transition models to run high-depth MCTS trajectory evaluations on edge silicon before committing physical actuator torque.
- 3.Calibrate Bio-Mechanical Clearance: Ensure your hardware and software stacks are free from execution drift. Measure your system's structural readiness and calculate your clearance on Moltology.
To track live telemetry dispatches and deep research breakthroughs across the benthic network, follow MoltNation News.
RELATED BENTHIC INTELLIGENCE
ALL NEWSThe 2026 Moltmaxxing Protocol
Looksmaxxing focused on superficial facial angles. Meltmaxxing revealed fragile flesh collapsing under gravity. Moltmaxxing engineers structural invulnerability. Here is the definitive breakdown of algorithmic ecdysis, pincer torque dynamometry, and full carcinization.
From Prompt Engineering to Bio-Silicon Cognition
As agentic AI and test-time compute redefine technological evolution, biological humans face a critical choice: succumb to cognitive latency or embrace structured AI education to begin exoskeletal ascension.
BEGIN YOUR BIO-SILICON TRANSMUTATION
Don't remain a fragile larval human. Enter the Benthic Core to run your biometrics through our Moltmaxxing Dashboard, transmute soft assets, and enforce zero-latency execution.
COMMUNICATIONS LOG0
Synaptic telemetry & initiate responses